HBB / Field robotics collection
Intelligence from the ground up.
Three approaches to observing soil, plants and the growing environment. Explore HBB Spider, Octa Rover and Strider, with the supplied concept artwork for each model.
Model 01 / Field robotics concept
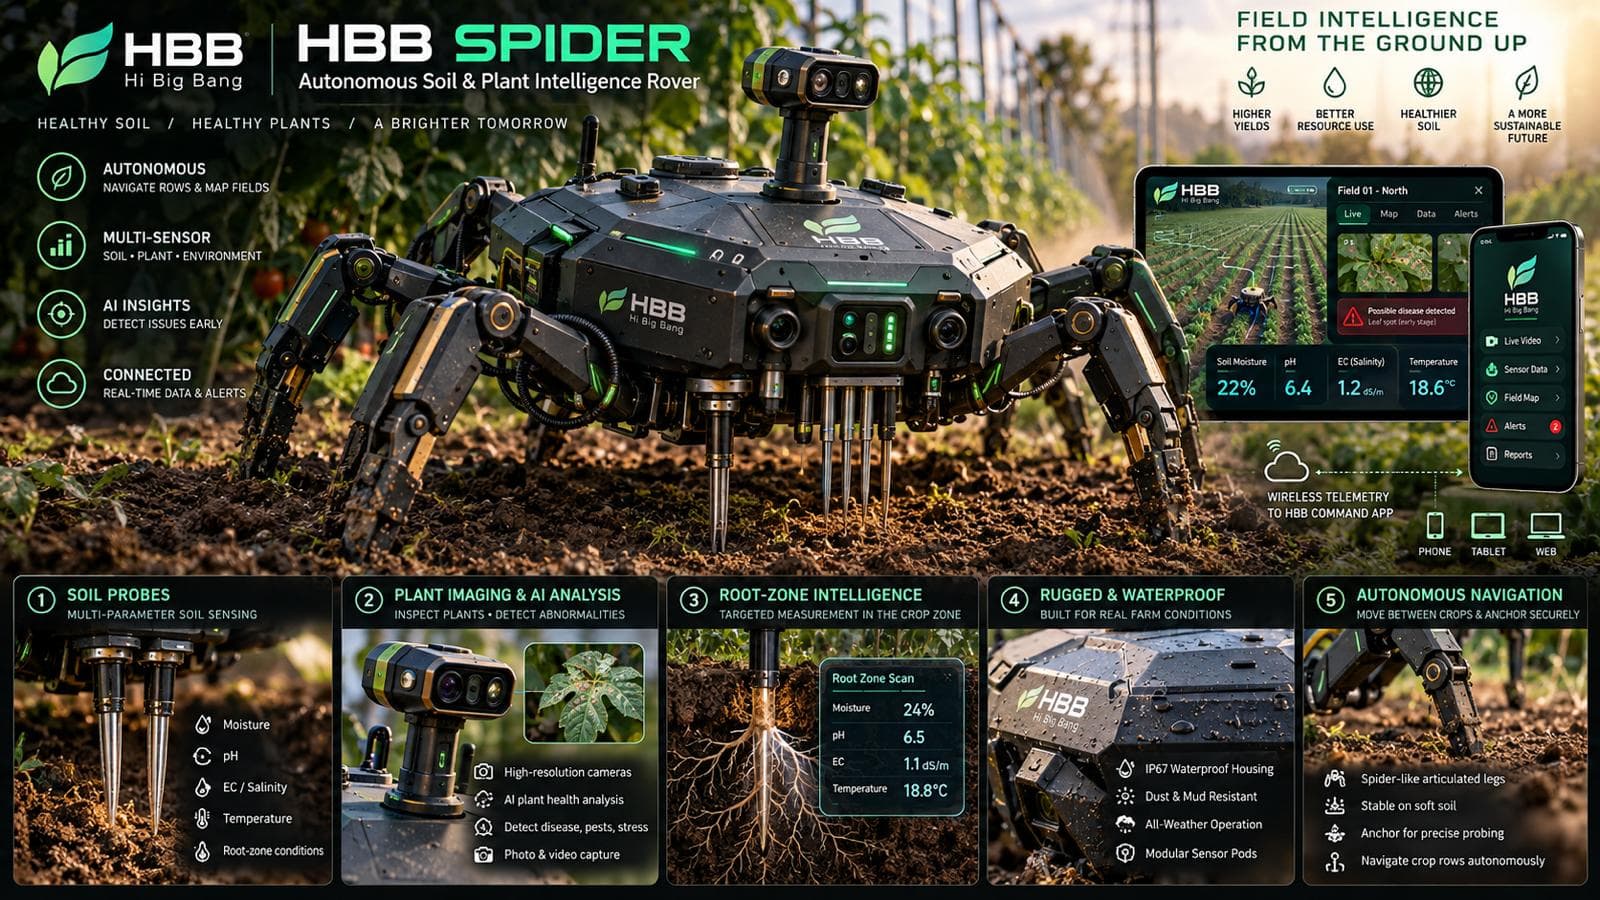
HBB Spider
Legged soil & plant intelligence rover
An articulated field robotics concept bringing root-zone sensing and plant observation together around the crop.
- Articulated legs for positioning between crops
- Proposed soil probes for root-zone context
- Plant imaging and a connected monitoring interface
Model 02 / Field robotics concept
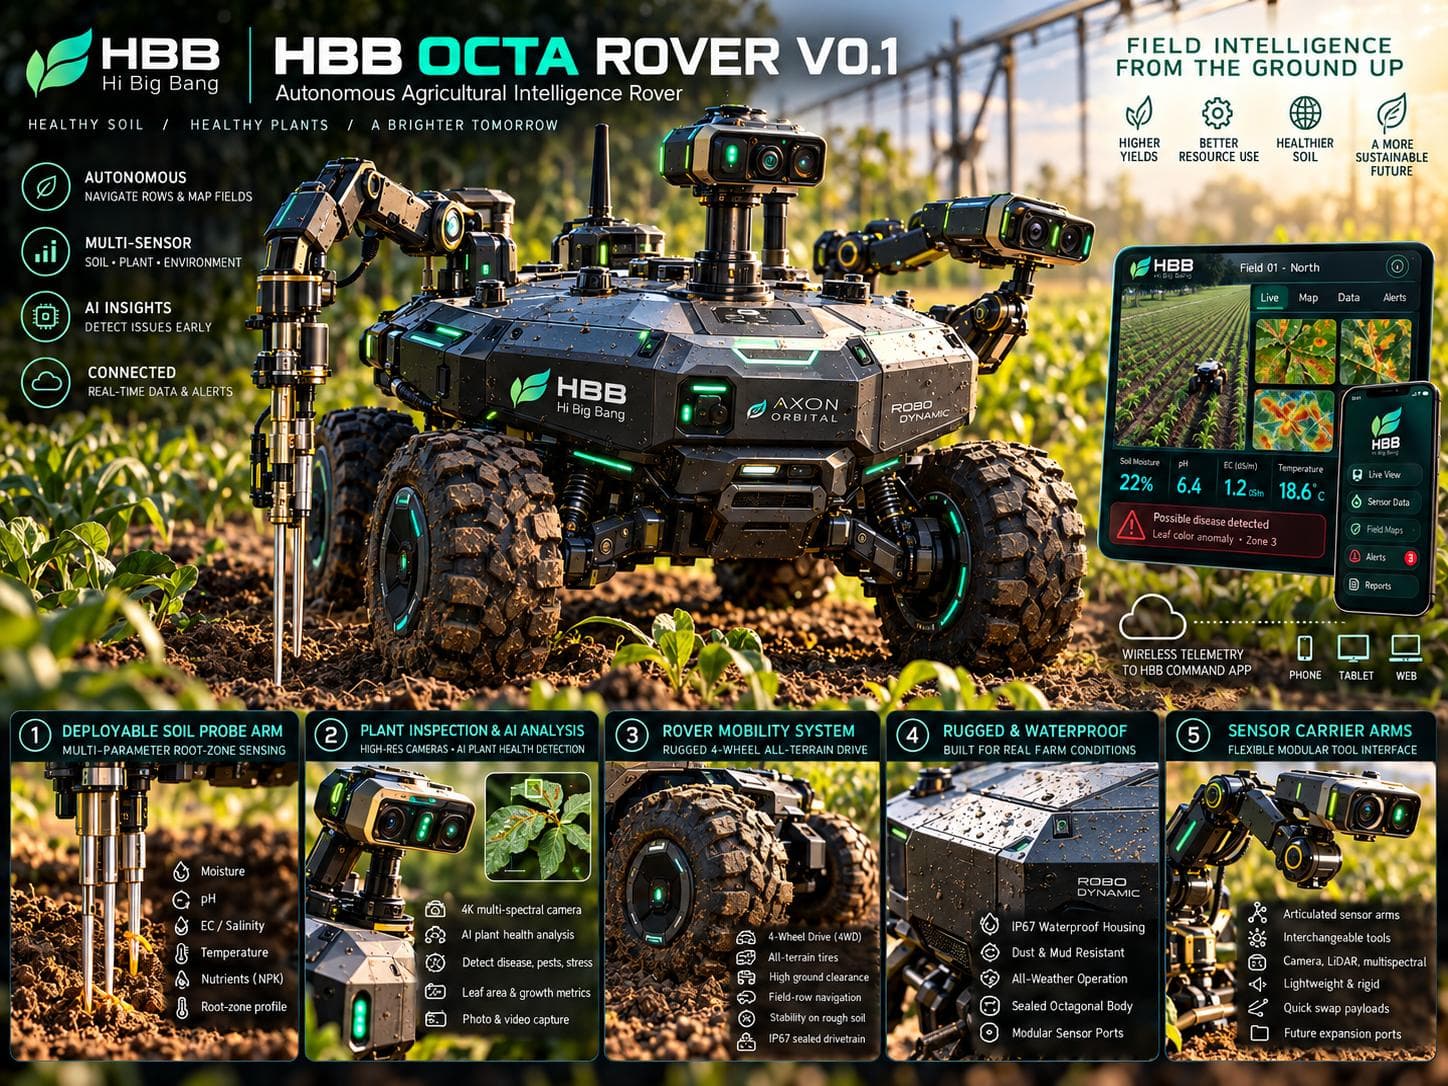
HBB Octa Rover V0.1
Wheeled agricultural intelligence rover
A wheeled platform concept with a deployable soil probe and sensor arms for observing plants and their growing environment.
- Four-wheel field mobility concept
- Deployable soil probe arm
- Modular camera and sensor carrier arms
Model 03 / Field robotics concept
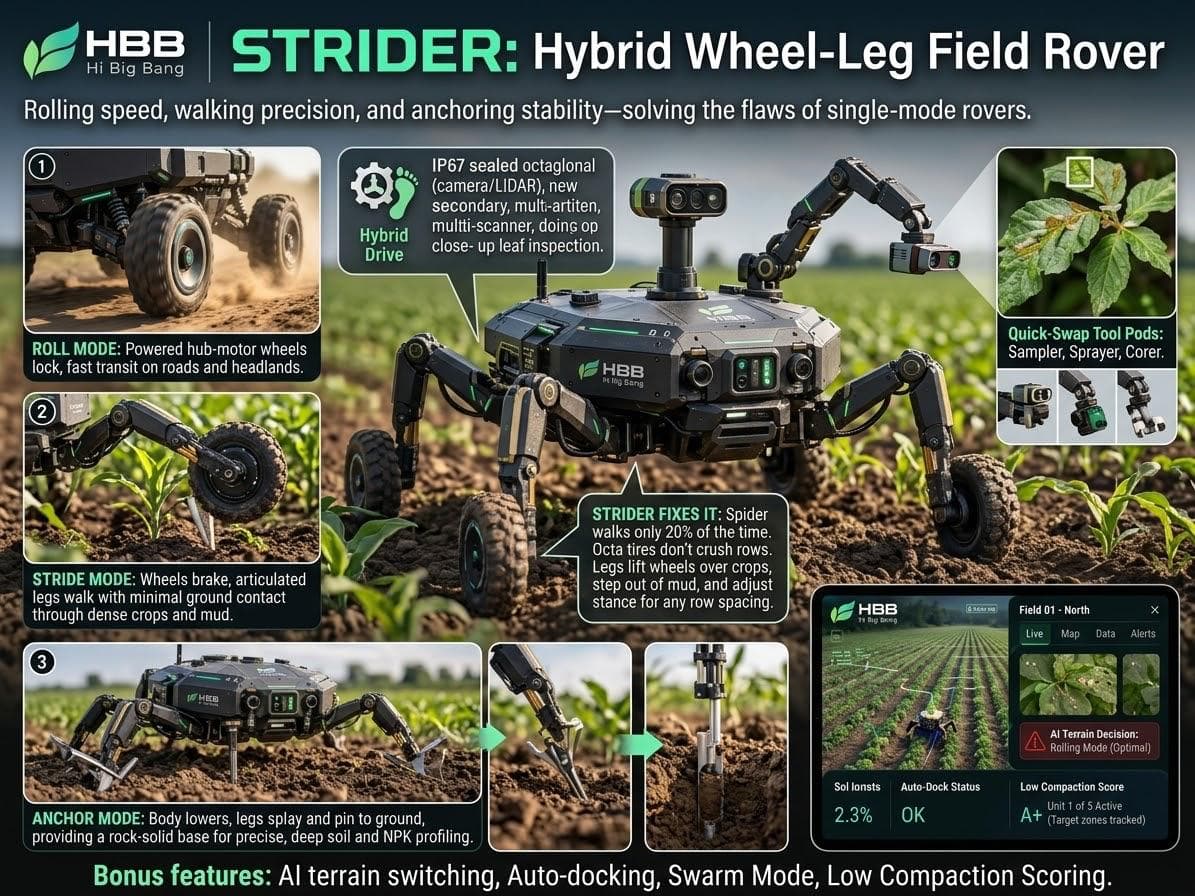
HBB Strider
Hybrid wheel-leg field rover
A hybrid concept combining rolling travel, articulated walking and a stationary anchoring stance for field observation and soil sampling.
- Roll, stride and anchor operating concepts
- Quick-swap tool pod concept
- Proposed terrain switching and docking workflows
Supplied technology concept artwork. Models, pictured measurements, performance claims and interface screens illustrate proposed capabilities. Hardware specifications and validation data are not yet supplied; pictured app screens are not live farm data.
Soil context
The concepts explore measurements around the plant root zone. Sensor specifications and validation data are not yet supplied.
Plant observation
The artwork explores imaging and plant observation. No diagnosis or automated crop analysis is available in this preview.
Connected fieldwork
A proposed connection between field devices and a monitoring app. Hardware integration and device telemetry are not connected.